Open industrial runtime pinned to 20260922.0
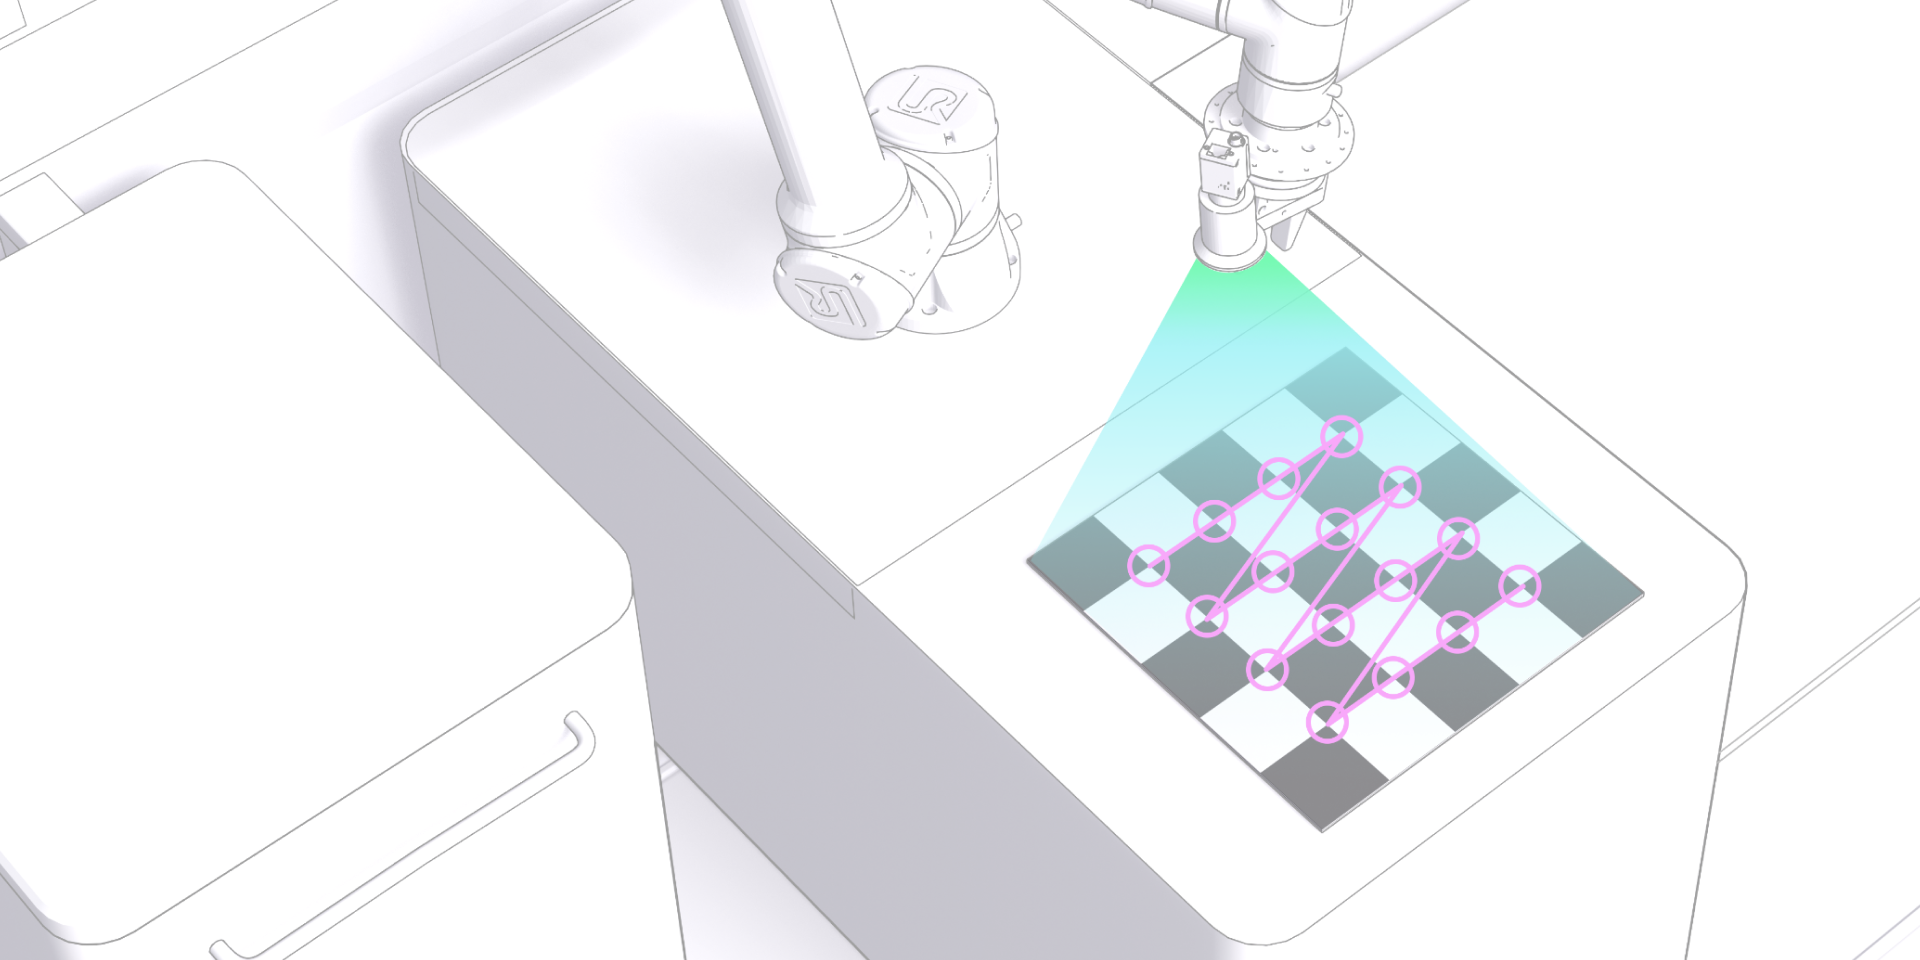
Caption: Intrinsic Core announcement hero · Source: Intrinsic blog, 22 September 2026 · link
Intrinsic Core is an open local robotics runtime, SDK, and hardware-agnostic real-time control stack for industrial / physical-AI apps. Intrinsic (a Google group) posted it at ROSCon 2026 in Toronto on 22 September 2026. Pin the dated tag 20260922.0.
Modules named in the README:
| Module | Role |
|---|---|
intrinsic_runtime | Local k3s execution engine (process life cycle, scheduling, state sync on ROS 2) |
intrinsic_control (ICON) | Real-time motion + HAL; swap arms/grippers/sensors without driver rewrites |
intrinsic_motion_planning | Collision-aware path generation (Cartesian + C-space) |
intrinsic_perception | Camera / point-cloud layer with NVIDIA FoundationPose 6-DoF pose |
intrinsic_inference | Edge ML serving into planning/control loops |
intrinsic_sdk / intrinsic_apis | Dev toolkit + interface defs |
intrinsic_hardware / intrinsic_kinematics | Device drivers/manifests + kinematic solvers |
Companion reference: Open Machine Tending Solution (OMTS) at intrinsic-omts. Glossary/tutorial framing: a Solution is software + config for one automation task; OMTS's task is CNC load/unload. Getting Started clones both repos at 20260922.0, installs k3s, then deploys intrinsic-base-linux-amd64.tar from that GitHub Release.
Prereqs (README / Getting Started): Ubuntu 24.04 or 26.04 (22.04 noted as supported in README; Getting Started centers 26.04 Desktop), ROS 2 Lyrical Luth, x86-64, heavy RAM/GPU asks for full OMTS+perception sim. ARM is unsupported for real-time control per the tutorial.
ROSCon 2026 drop and OMTS on-ramp
ROSCon 2026 was the public drop point. The blog frames Core as the same class of building blocks Intrinsic says it uses for manufacturing work, released under Apache 2.0 so integrators can run on local hardware with ROS-compatible services (ICON control, FoundationPose pose, motion/grasp planning, Gazebo sim, camera calibration, Intrinsic-ROS drivers).
OMTS is the Monday on-ramp: a pre-configured machine-tending reference that the product page says partners with assets from NVIDIA, Universal Robots, FANUC, ATI, Schunk, Robotiq, and Basler. Separately this week Intrinsic cited an AI for Industry Challenge with 5,000+ developers across 115 countries. Treat that figure as developer-interest context. Core install counts are not disclosed.
(Feb 2026 Intrinsic-joins-Google posts are older org context only. They are not this open-source drop.)
Apache-2.0 tags and usable maturity
- License: Apache License 2.0 (
LICENSEin the repo). Contributions require the Google CLA perCONTRIBUTING.md. - Activity: Public tags
20260921.0and20260922.0(commit subject: "Update tags for 20260922.0 release"). Getting Started and related tutorials ship in-tree. GitHub REST API was rate-limited during this draft, so star counts are omitted. - Maturity: usable. Real SDK + docs + dated release tarball + OMTS reference. README disclaimer: not an officially supported Google product. Vendor marketing talks about paths from prototype toward enterprise Intrinsic offerings; treat Core itself as early open infra you must validate on your workcell. Do not read our label as a production SLA.
OMTS machine-tending vs stock ROS 2
| Situation | Lean Intrinsic Core + OMTS | Lean the ROS 2 default stack |
|---|---|---|
| You want a pre-wired industrial runtime (k3s + ICON HAL + FoundationPose path) and will follow Intrinsic's Getting Started | Pilot on Ubuntu 26.04 / Lyrical Luth at tag 20260922.0 | Keep stock stack |
| You already ship MoveIt 2 + Gazebo / Ignition with in-house drivers and need only one new planner | Skip Core for now | Stay on MoveIt / community drivers; optionally evaluate intrinsic-moveit as a bridge |
| Machine-tending CNC load/unload prototype with UR / FANUC-class assets named in OMTS | Start from OMTS, customize skills | Build a custom MoveIt + behavior-tree cell |
| Regulated line needing a Google-backed support contract on day one | Skip open Core as the support vehicle | Enterprise Intrinsic commercial path, or keep incumbent integrator stack; Core README disclaims official Google product support |
| ARM or non-Ubuntu laptop-only tinkering | Skip | Plain ROS 2 desktop installs |
Monday clone (from Getting Started):
gh repo clone intrinsic-ai/intrinsic-core -- --revision=20260922.0
gh repo clone intrinsic-ai/intrinsic-omts -- --revision=20260922.0
Then run the documented k3s setup and gh release download --repo intrinsic-ai/intrinsic-core 20260922.0 --pattern intrinsic-base-linux-amd64.tar.
No Google support and Lyrical Luth lock
- Support disclaimer: bugs and security follow the public repo (
SECURITY.md); there is no implied Google product support from the README. - Hardware / OS tax: real-time control wants Intel x86-64; full OMTS+perception sim wants a dedicated NVIDIA GPU and 32 to 64 GiB RAM. Under-spec machines fail late in bring-up.
- ROS distro lock: Lyrical Luth is the stated target. Mixing older Humble/Jazzy workspaces will fight the pre-configured runtime.
- Vendor path vs Core-only: blog says Core-built solutions can move onto Intrinsic Flowstate / cloud enterprise services without rewrites. That path is vendor-described; open Core alone does not give you those services.
- Trademark / CLA friction: "Intrinsic" / "Intrinsic Core" marks plus Google CLA for contributions can slow forks and commercial branding.
- Fresh drop: first public tags are mid-September 2026. Expect broken tutorials and hardware matrix gaps until independent builds accumulate.
Links
- Blog: Introducing Intrinsic Core (22 Sep 2026)
- Repo (pin
20260922.0): github.com/intrinsic-ai/intrinsic-core - Product page: intrinsic.ai/intrinsic-core
- OMTS: github.com/intrinsic-ai/intrinsic-omts
- Getting Started: getting_started.md
- Developer community: developer.intrinsic.ai